Flagship project
01 — Autonomous robotics platform
Paesano
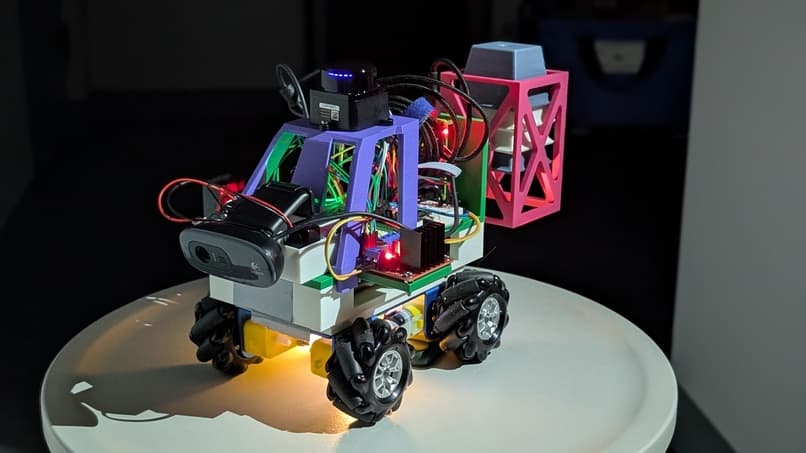
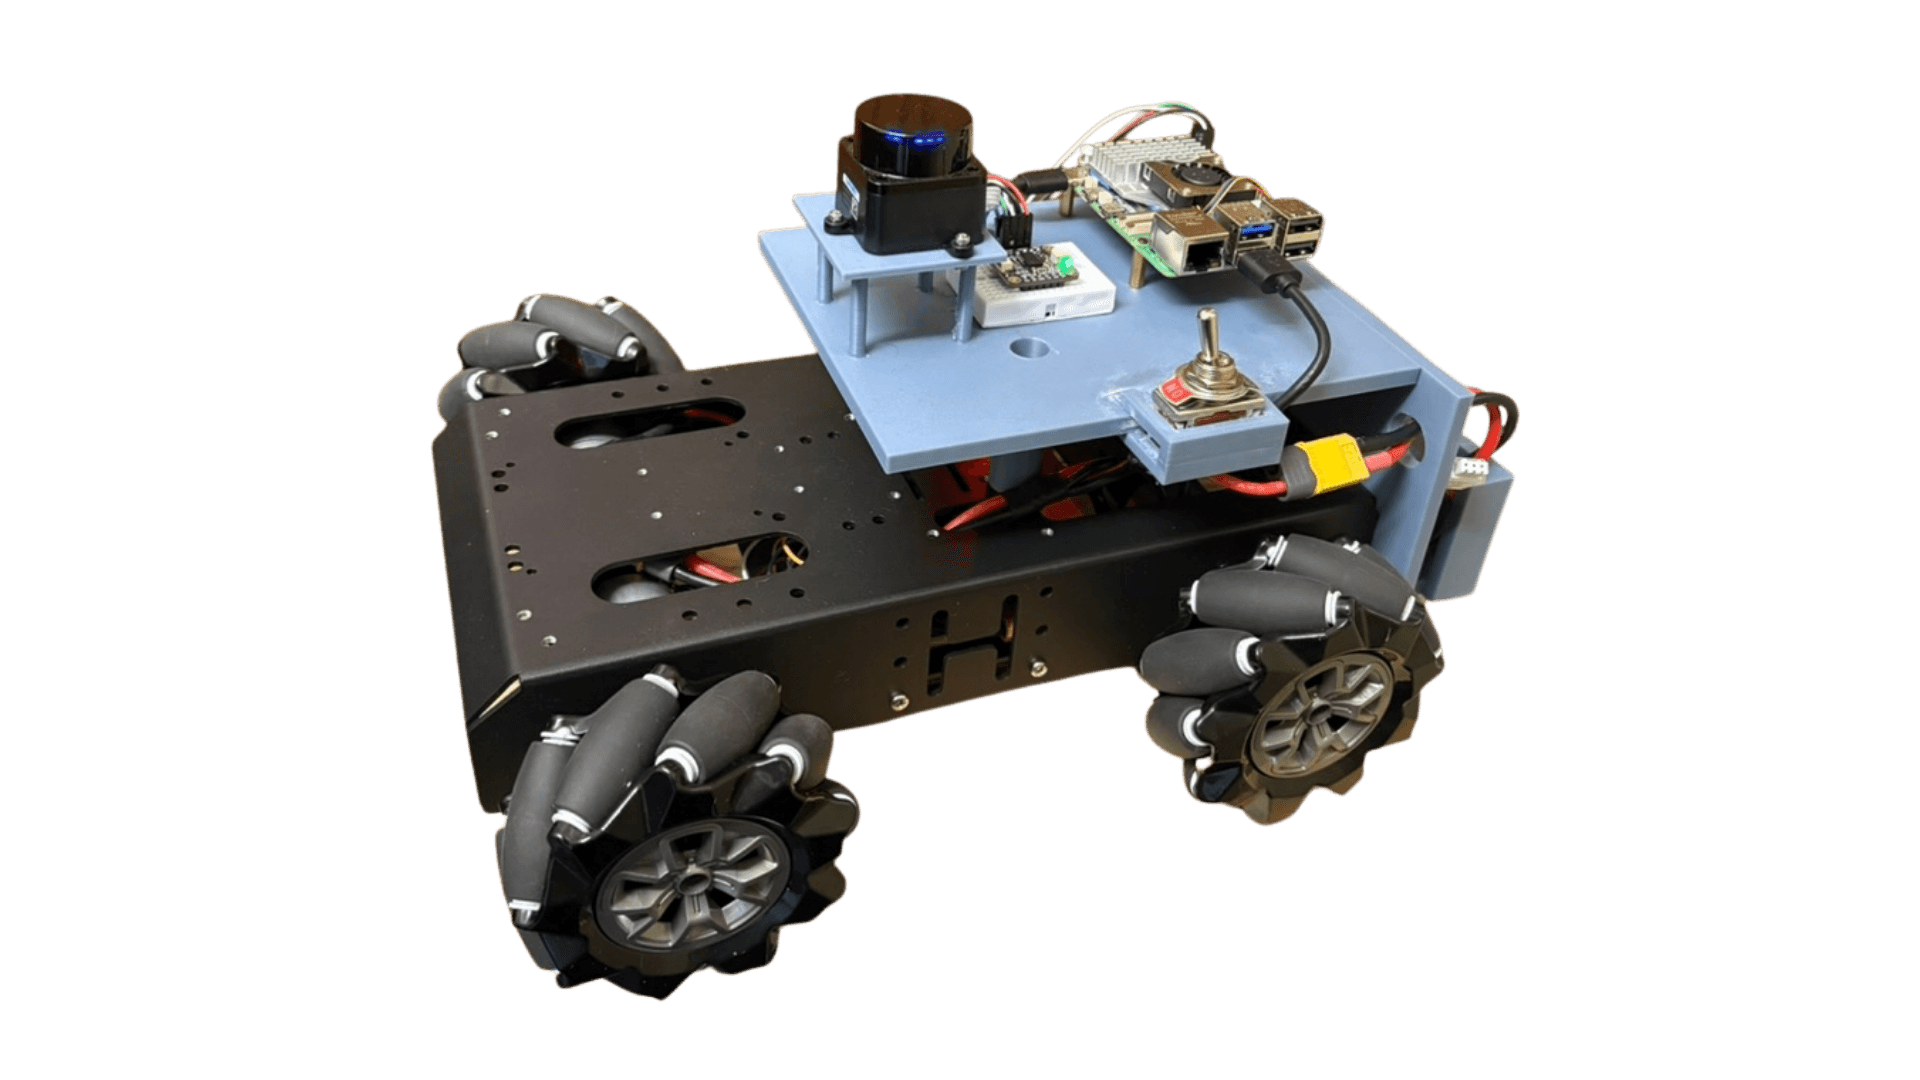
A holonomic indoor robot with a ROS 2/C++ autonomy stack. A Raspberry Pi 5 handles planning and estimation; a Pico runs a 50 Hz cascaded motor controller. The goal was a robot I could measure, debug, and improve on real hardware.
Perception & pose
LD19 LiDAR, BNO085 IMU, wheel encoders, EKF fusion, and a particle-filter localizer written from scratch.
Motion & planning
Mecanum drive control, spline trajectories, LQR path tracking, A* planning, and frontier exploration.
Tested on hardware
Completed 9/9 navigation routes; rosbag analysis measured 0.9 cm mean cross-track and 0.6 cm final-position error.
Built end to end
Custom C++ ROS 2 nodes, embedded firmware, simulation, and a SwiftUI app with a FastAPI/WebSocket bridge.
Hardware demo
View on YouTube